Remo Description
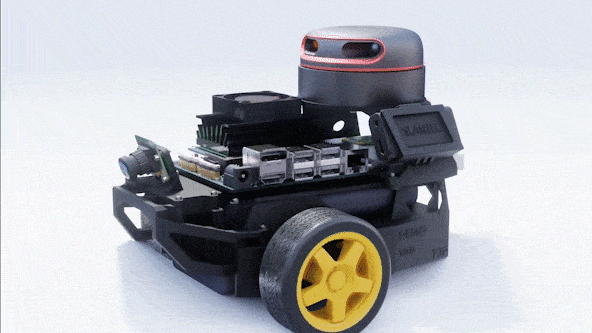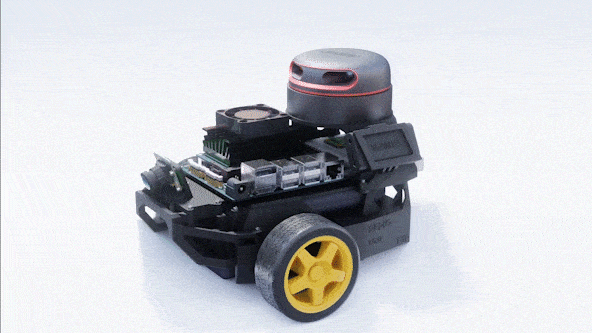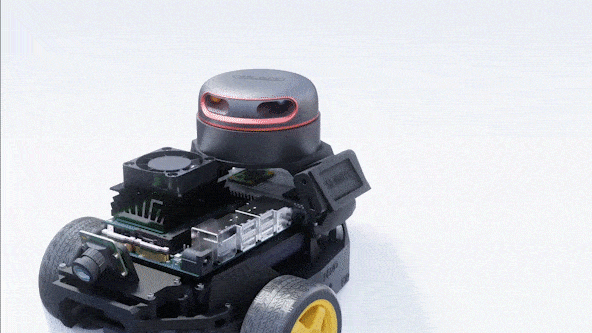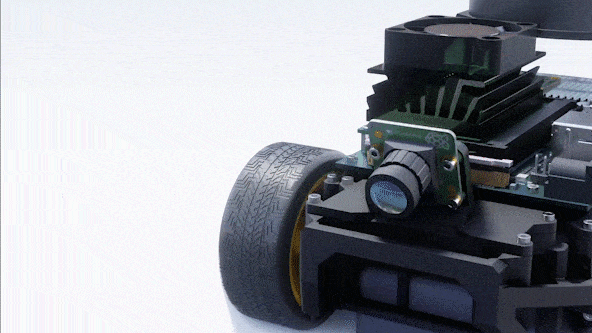
ROS URDF description package of REMO robot (Research Education Mobile/Modular robot) a highly modifiable and extendable
autonomous mobile robot based on Nvidia's Jetbot.
This ROS package is in the remo_description repository. It describes Remo for RViz and Gazebo; the STL files to 3D print it are described below.
You can explore the model in more detail through the following Fusion 360 viewer:
Usage
This is a ROS package which should be cloned in a catkin workspace.
To use remo_description inside a Gazebo simulation or on a real 3D printed Remo robot, you can directly make use of the ROS packages in the
ros-mobile-robots/diffbot repository.
Most of the launch files you find in the diffbot repository
accept a model argument. Just append model:=remo to the end of a roslaunch command to make use of this remo_description package.
STL files
The public remo_description repository has empty placeholder STL files, so Remo has no meshes in RViz and Gazebo, and there is nothing to print. There are two ways to get the real files:
-
Buy the STL files
A one-time payment on Gumroad. You download all of Remo's STL files and can start printing, and the purchase supports this project.
-
Sponsor and get Remo Insiders
From $10 a month on GitHub Sponsors. You get Remo Insiders, a private Git repository with the STL files that you clone and pull, and new features first.
After buying them on Gumroad, download them into the repository with the configuration file, as described in its README. With Remo Insiders, clone the private repository instead, see Remo STL files.
Which parts to print and how: 3D Printing.
Assembly
For assembly instructions please watch the video below:
Camera Types
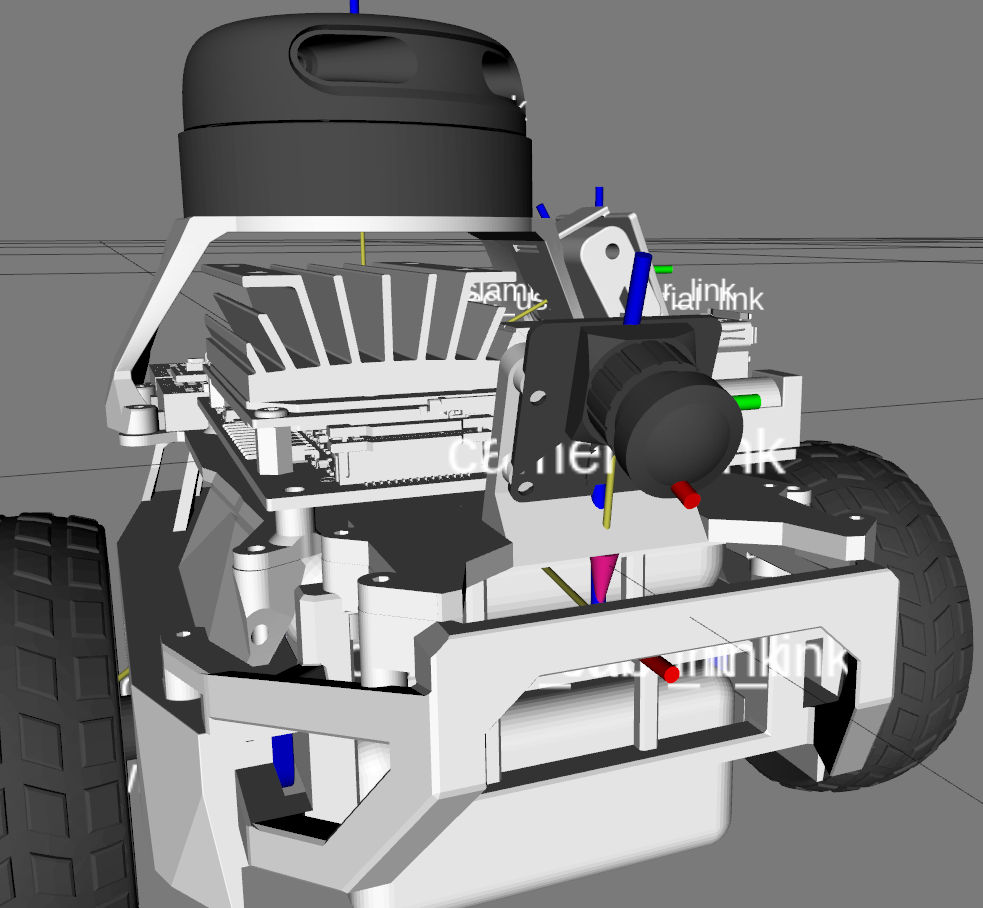
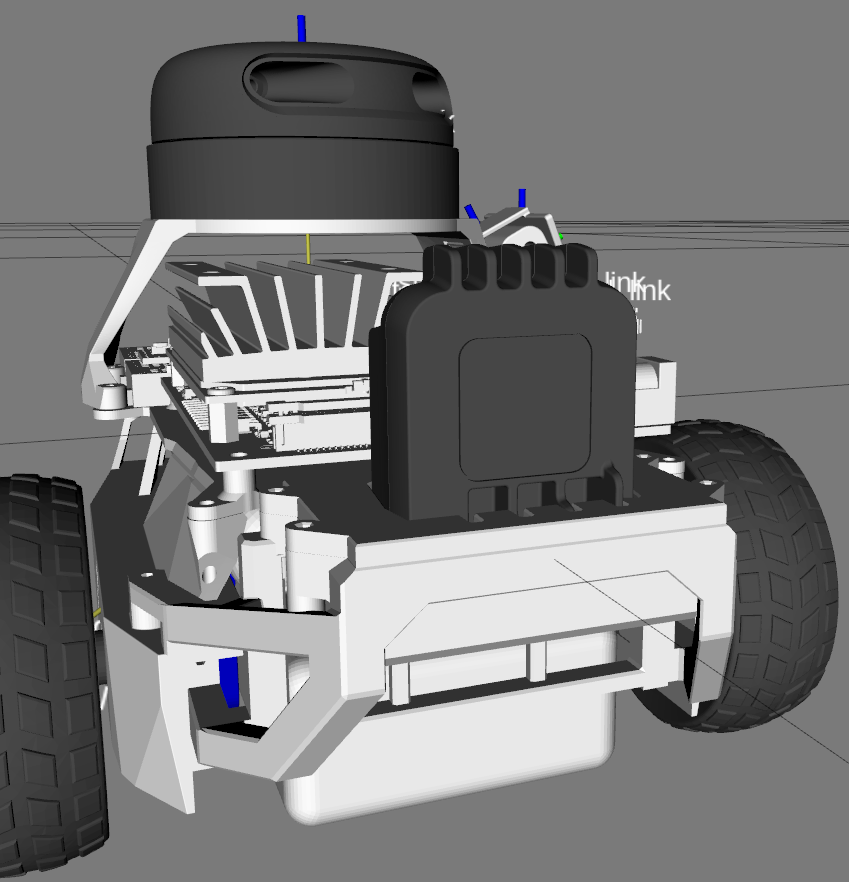
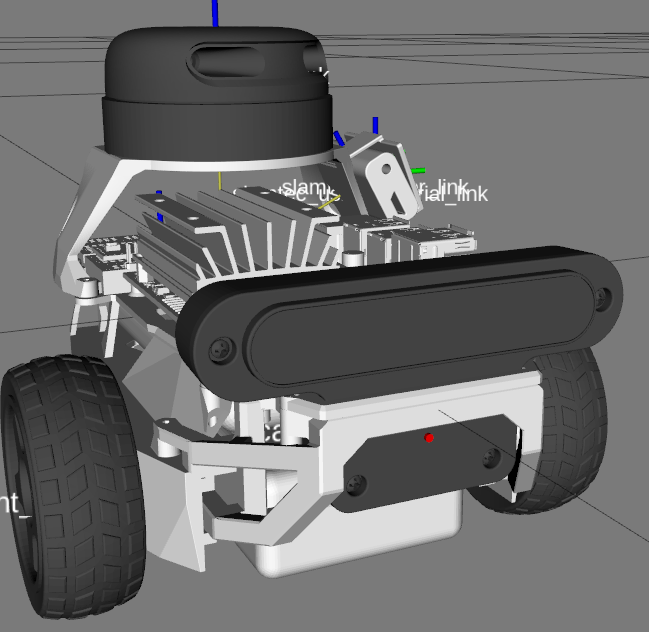
The remo.urdf.xacro accepts a camera_type
xacro arg which lets you choose between the following different camera types
| Raspicam v2 with IMX219 | OAK-1 | OAK-D |
|---|---|---|
 |
 |
 |
Single Board Computer Types
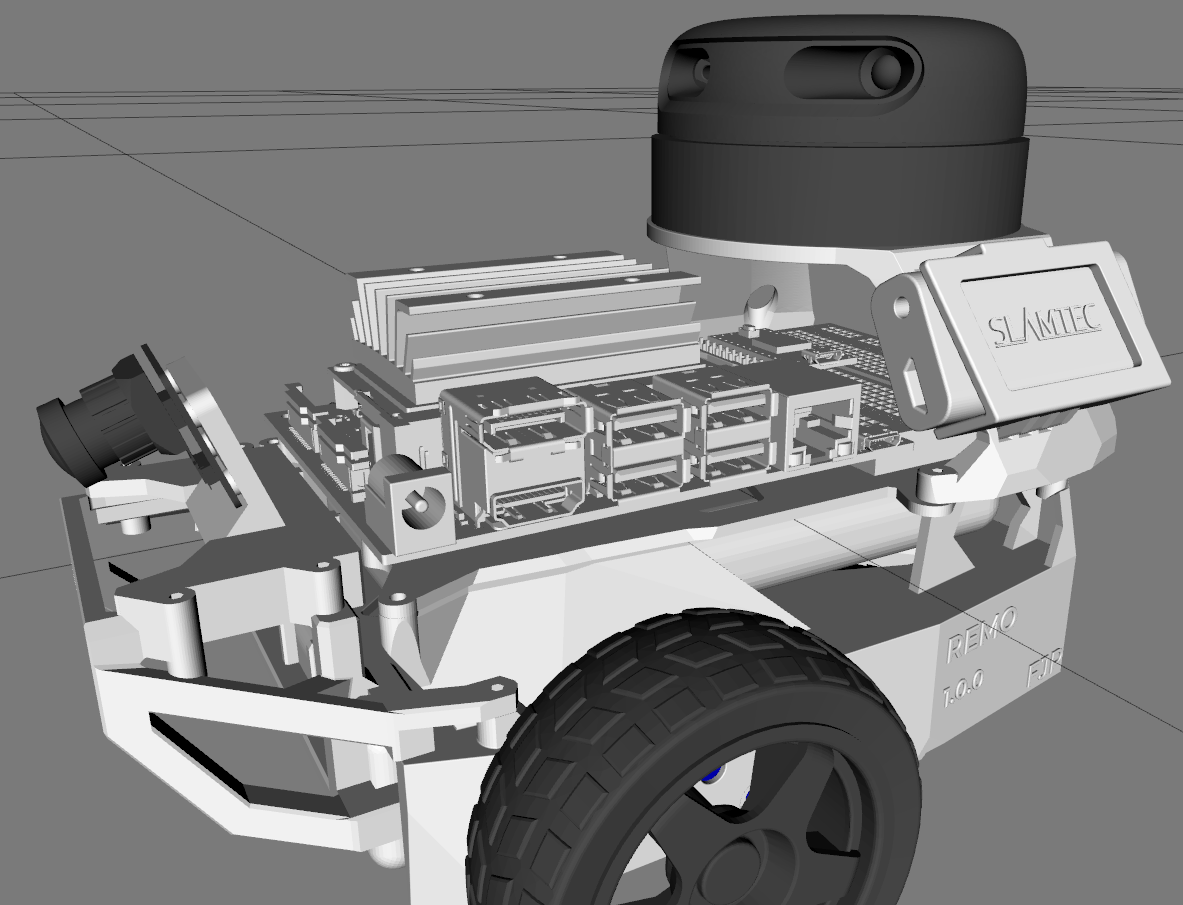
Another xacro argument is the sbc_type where you can select between jetson and rpi.
| Jetson Nano | Raspberry Pi 4 B |
|---|---|
 |
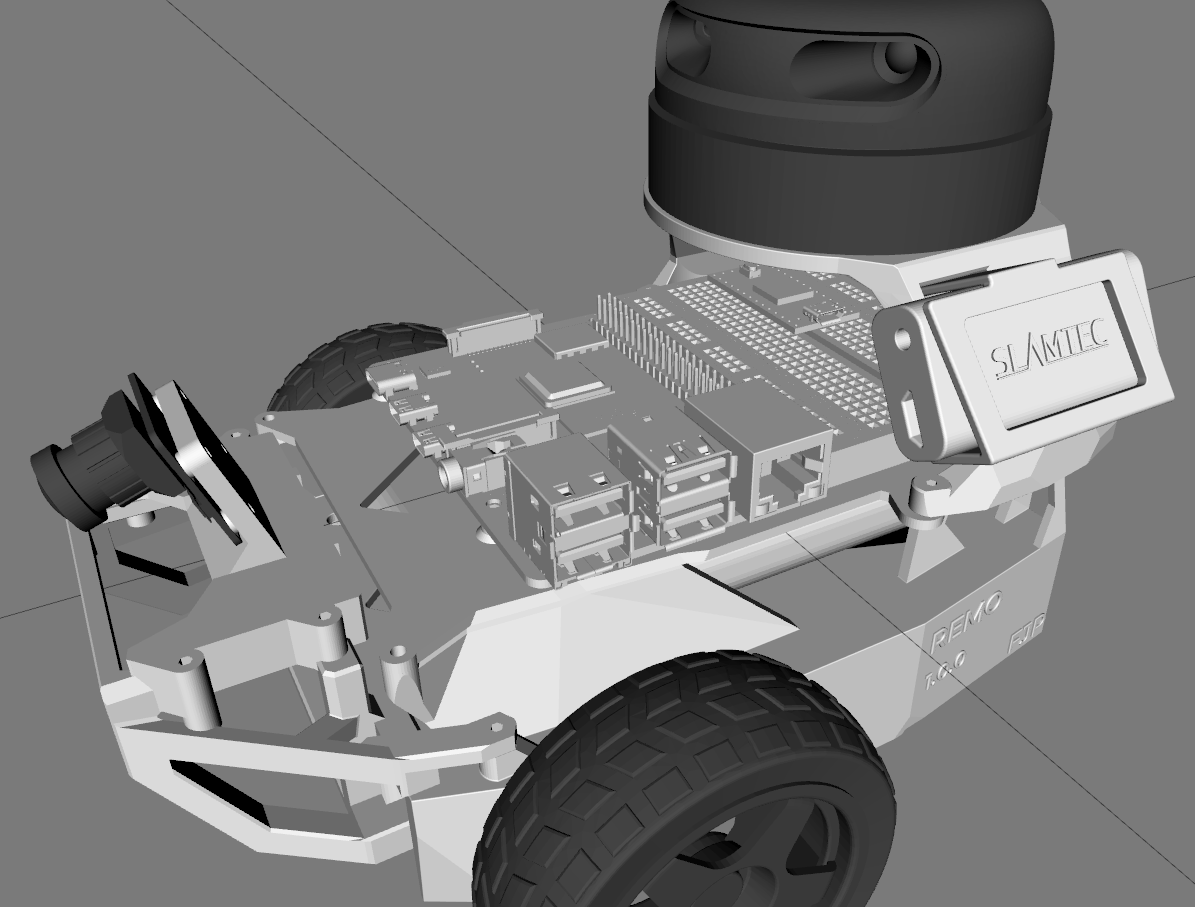 |
 Acknowledgment
- Louis Morandy-Rapiné for his great work on REMO robot and designing it in Fusion 360.
References
Comments
Comments are GitHub Discussions, shown with giscus. Loading them connects to giscus.app (hosted by Vercel, USA) and GitHub (USA); you need a GitHub account to comment.