3D Printing
This page provides help to 3D print the parts of Remo robot. It contains information about configuring your slicer, suggestions to orient the parts and where support material is recommended to avoid failing prints and wasted PLA material.
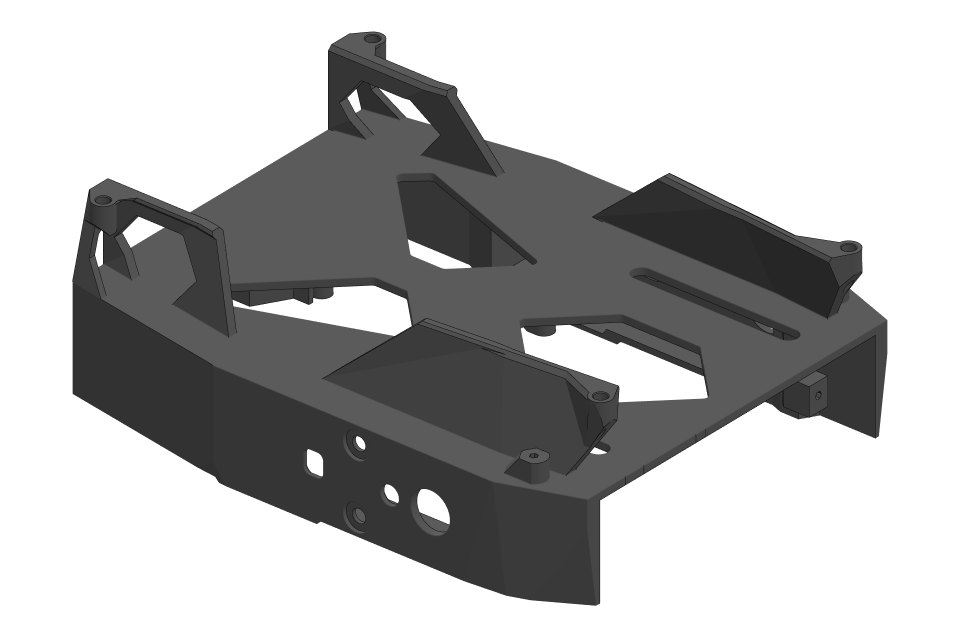
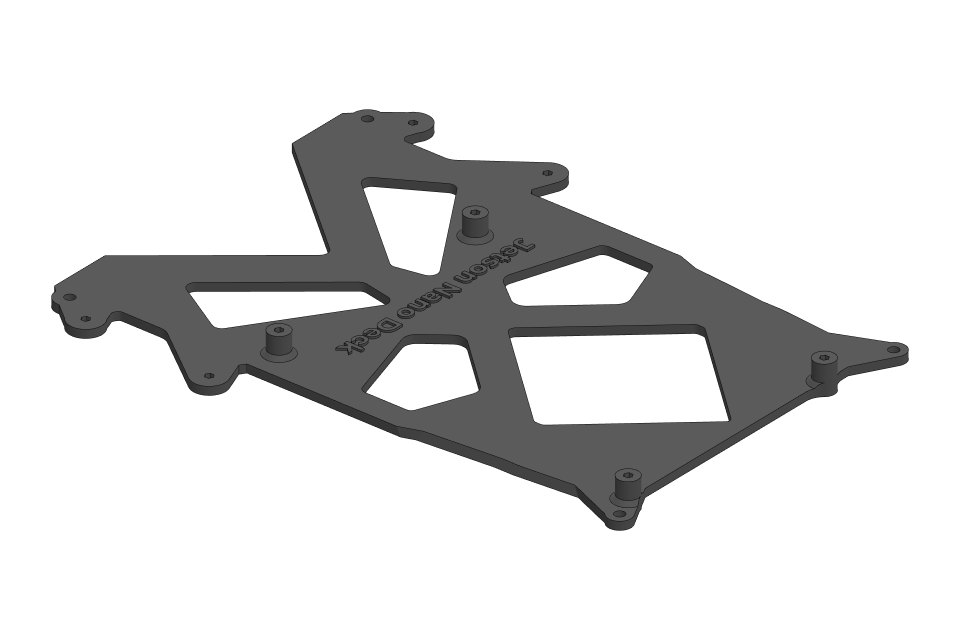
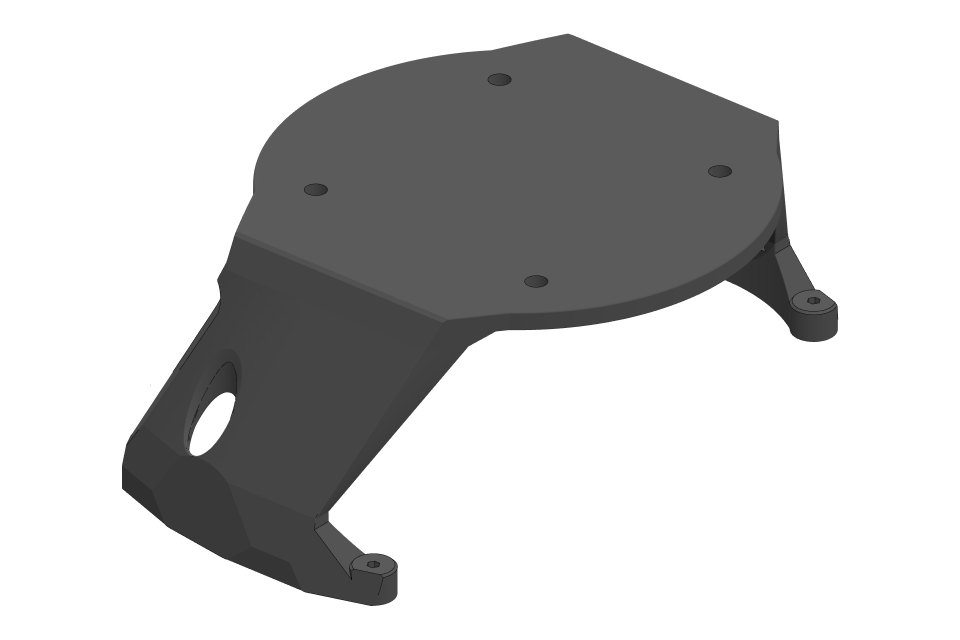
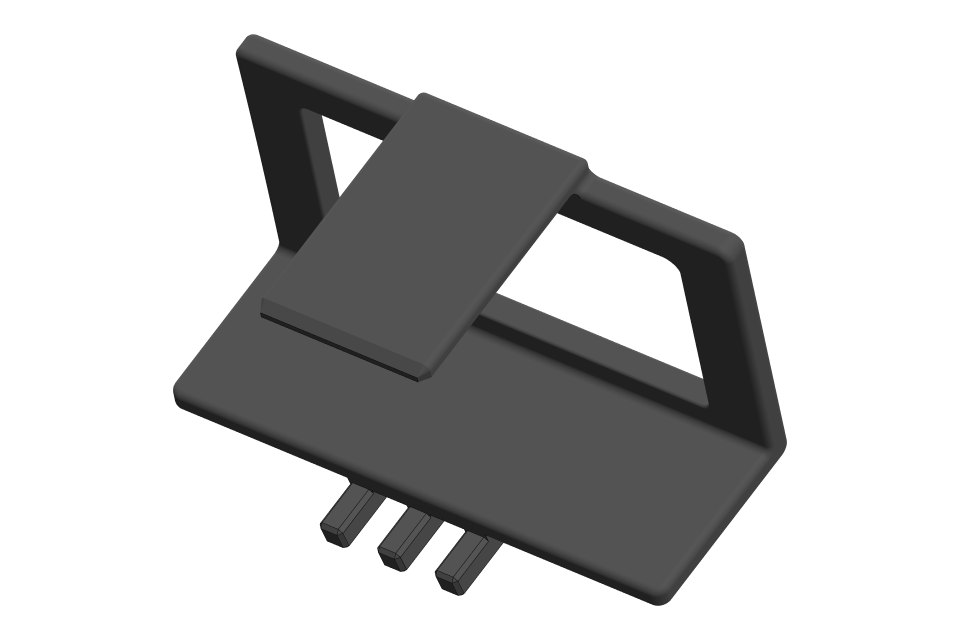
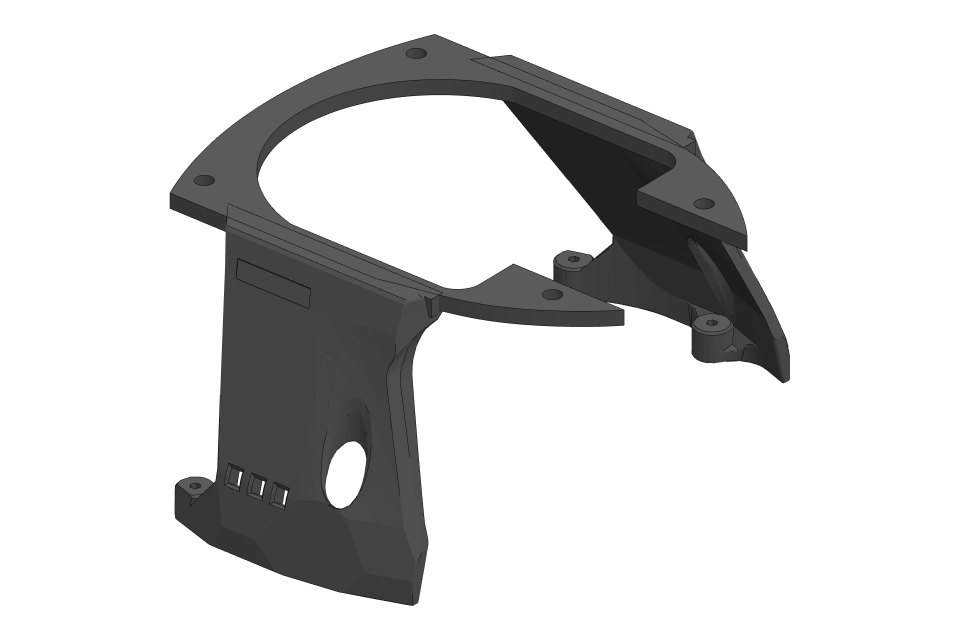
The STL files for all parts below are available on Gumroad; buying them also supports this project. The remo_description repository on GitHub only has empty placeholders for them. The images on this page are renders of the STL files.
The table below gives an overview of the required parts of Remo and the average printing time:
Note
Remo robot is a modular robotics platform which means you don't have to print all parts. It is often possible to choose between different variants. For example:
- SBC Deck
- LiDAR Platform
- Camera Mount
| Qty | Part | File | Material | Time | Notes |
|---|---|---|---|---|---|
| 1 | Chassis | chassis.stl |
PLA | ||
| 1 | Caster wheel | caster_base_65mm.stl and caster_shroud_65mm.stl |
PLA | Print both parts of the caster wheel | |
| 1 | SBC deck | raspberry_pi_deck.stl or jetson_nano_deck.stl |
PLA | Select one depending on your SBC | |
| 1 | LiDAR platform | platfom_rplidar_a2.stl or platform_rplidar_a1.stl |
PLA | Select one depending on your LiDAR | |
| 1 | SLAMTEC USB adapter holder | slamtec_holder.stl |
PLA | ||
| 1 | Camera mount | camera_mount.stl and one camera adapter |
PLA | Select the adapter for your camera |
Chassis
Caster Wheel
| Qty | Part | Render |
|---|---|---|
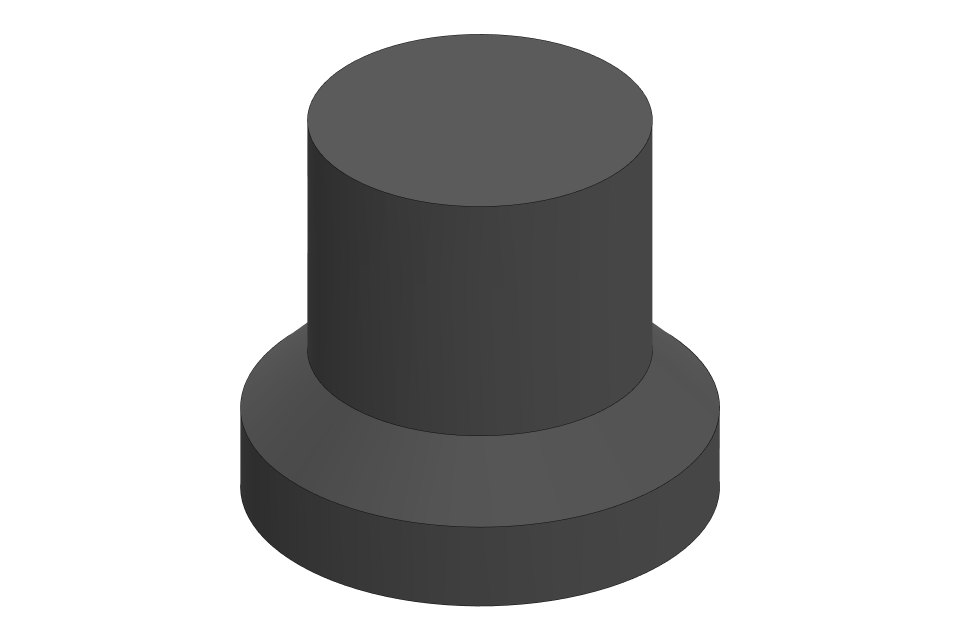
| 1 | caster_base_65mm.stl |
 |
| 1 | caster_shroud_65mm.stl |
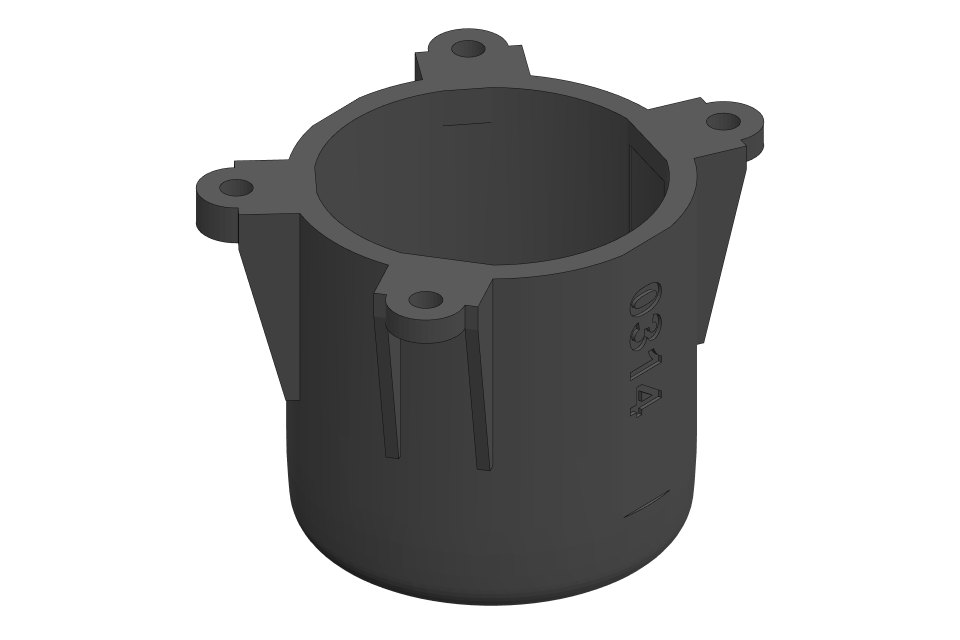 |
The caster needs a 25.4 mm (1 inch) ball, see the components.
SBC Decks
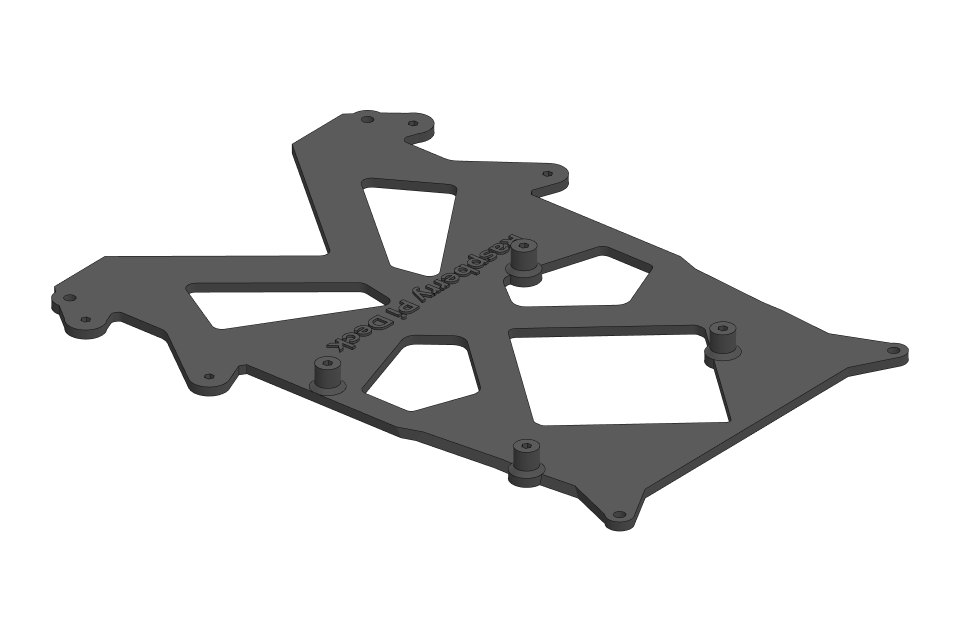
There are two decks, one for each single-board computer:
| Qty | Part | Render |
|---|---|---|
| 1 | raspberry_pi_deck.stl |
 |
| Qty | Part | Render |
|---|---|---|
| 1 | jetson_nano_deck.stl |
 |
LiDAR Platform
| Qty | Part | Render |
|---|---|---|
| 1 | platfom_rplidar_a2.stl |
 |
| 1 | slamtec_holder.stl |
 |
| Qty | Part | Render |
|---|---|---|
| 1 | platform_rplidar_a1.stl |
 |
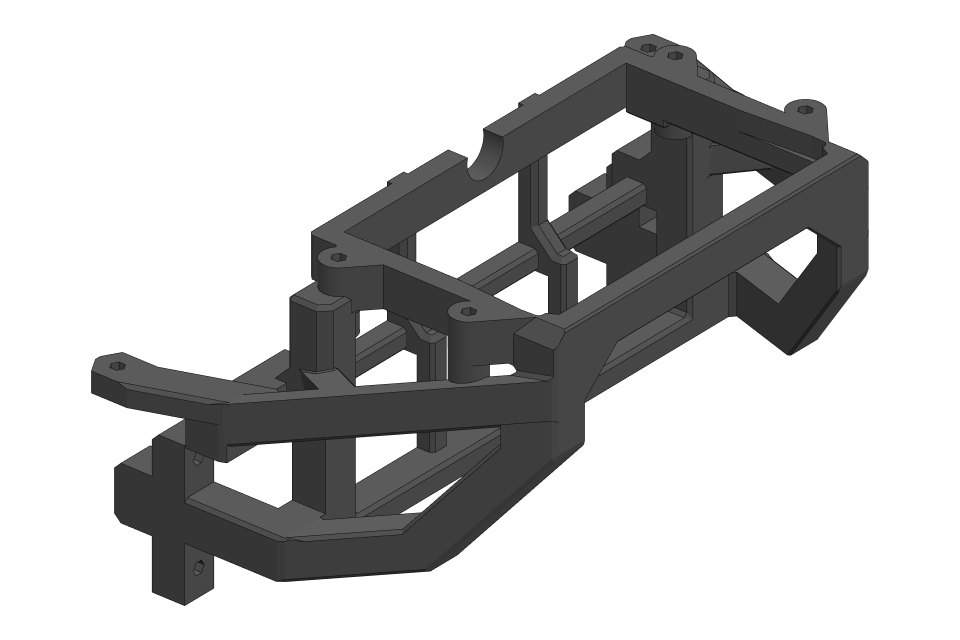
Camera Mount
| Qty | Part | Render |
|---|---|---|
| 1 | camera_mount.stl |
 |
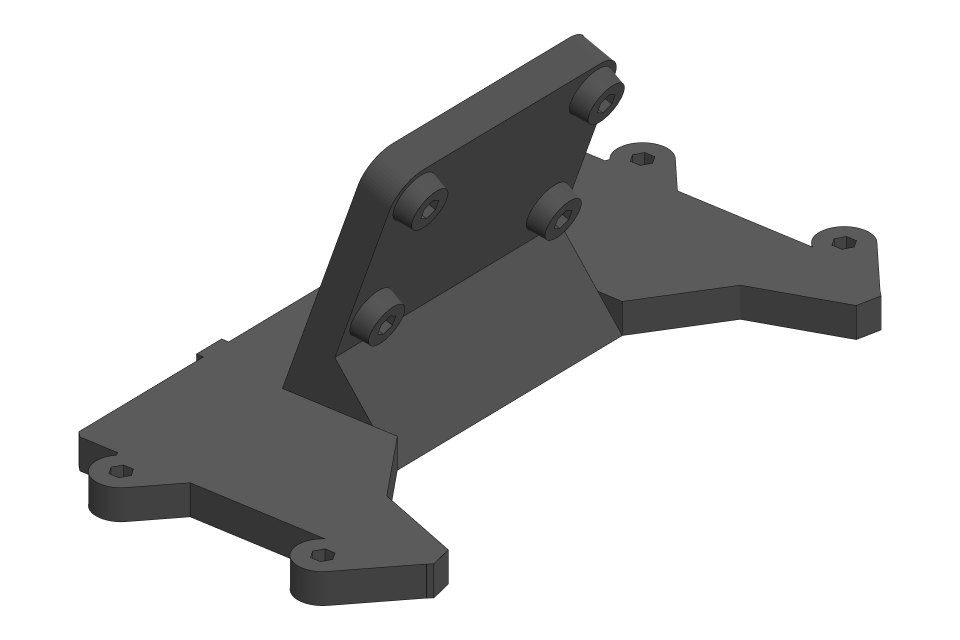
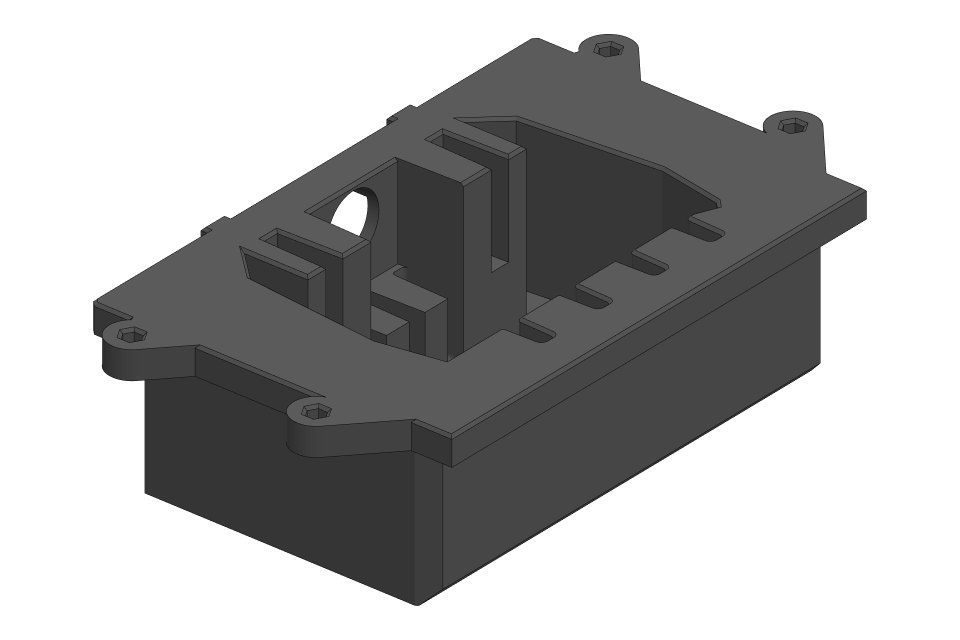
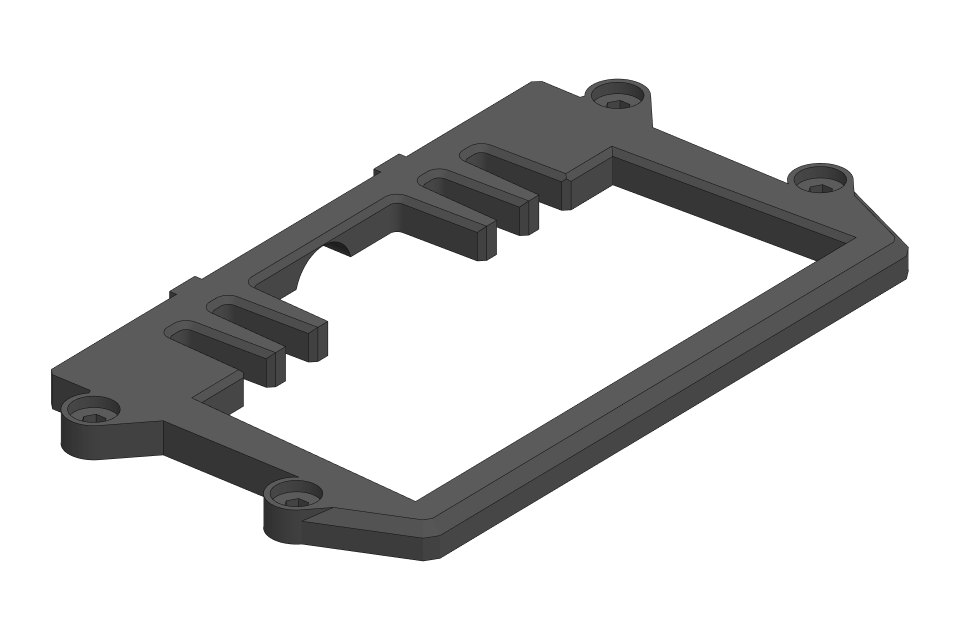
The camera mount takes an adapter for your camera:
| Qty | Part | Render |
|---|---|---|
| 1 | Raspberry_pi_CAM_holder.stl |
 |
| Qty | Part | Render |
|---|---|---|
| 1 | OAK-1_adjustment_mount.stl |
 |
| Qty | Part | Render |
|---|---|---|
| 1 | OAK-D_adjustment_mount.stl |
 |
Comments
Comments are GitHub Discussions, shown with giscus. Loading them connects to giscus.app (hosted by Vercel, USA) and GitHub (USA); you need a GitHub account to comment.